Transfer Lifts: Heave Compensation Between Two Moving Bodies
A transfer lift moves a load between a crane and a deck that move independently: a supply vessel and a platform, two vessels, or a barge and a crane vessel. What their relative motion does at pickup and set-down, and what a heave compensator can and cannot do about it.
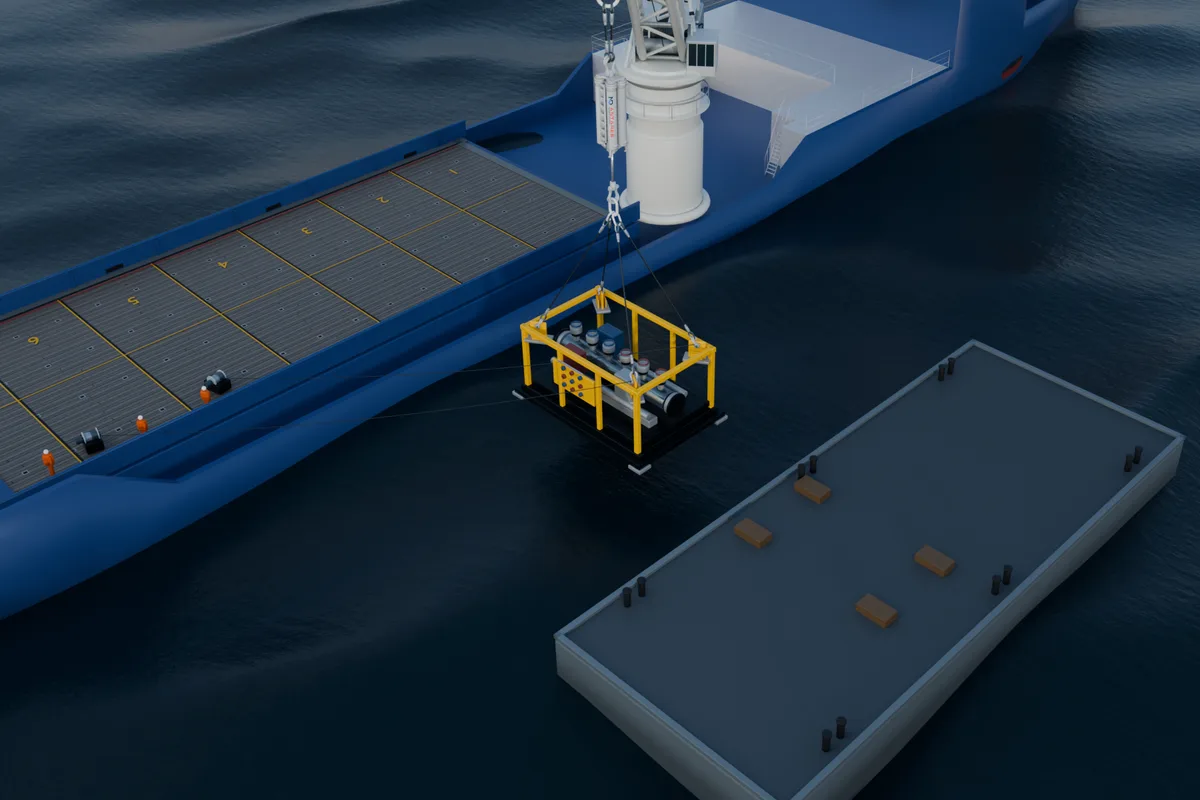
- The load case is the relative motion between the crane tip and the deck the load leaves or lands on. The deck moves with its own response to the waves, and so does the crane tip unless it stands on a fixed platform; the two are often out of phase.
- At pickup, slack slings snatch taut when the deck falls away as the crane tip rises: the load has to jump from the deck’s speed to the hook’s in an instant. DNV-RP-N103 gives that snap load from the hoisting speed, the relative velocity, the stiffness of the hoisting system and the load’s mass.
- At set-down, a deck rising under the load meets it at the sum of the two speeds and can strike it again after touchdown.
- A passive compensator makes the hoisting system soft, so the snatch at pickup becomes a slower, smaller take-up, and the slings do not snatch after touchdown. It does not slow a rising deck or follow it; that takes active control that measures that deck. Lifting the load clear of the deck fast, as the ANTARES quick lift does, is the other half of a safe pickup.
On a lift from the crane vessel’s own deck, the crane tip and the deck move together and lift-off is simple. In a transfer they move separately, so the load has to leave or meet a deck that moves relative to the hook.
Two moving bodies, one load
The motion that matters is the difference between the crane tip and the other deck. From a crane on a fixed platform, the crane tip stands still and the supply vessel’s deck does all the moving. On a floating platform, such as an FPSO or a semi-submersible, the crane tip moves too. Between two floating vessels both move, each with its own response to the same waves: different sizes, headings and natural periods give different amplitudes and phases. When the two move out of phase, the relative motion can approach the sum of both; in phase, they partly cancel.
The crane tip’s own motion grows with its outreach from the vessel’s centreline, where roll adds to heave, and with its distance from midships, where pitch does. The same goes for the spot on the other deck: a supply vessel’s cargo deck runs aft to the stern, where pitch adds most. An offshore crane’s load chart already derates its capacity for lifts from a supply vessel, with a dynamic factor built from the same relative motion; see crane load charts.
Pickup: slack, then snatch
Before lift-off the load rests on the deck on slack slings, and the crane takes up the slack as it hoists. If the deck falls away while the crane tip rises, the slings come taut in an instant and the load leaves the deck with a jerk: it has to go from the deck’s speed to the hook’s at once. DNV-RP-N103 gives the snap load at lift-off from the hoisting speed v_c, the vertical relative velocity between the load and the crane tip v_{rct}, and the stiffness K of the hoisting system, with M the mass in air:
The snap load grows with the square root of the stiffness. Take a 100 t load hoisted at 0.25 m/s off a deck moving at 1.0 m/s relative to the crane tip, on a hoisting system of 10 MN/m: the snap load is 1,250 kN, on top of the 981 kN weight. A compensator that makes the system 100 times softer cuts the snap load to a tenth, 125 kN, but it takes up 1.25 m of stroke to do it, and the natural period of the lift grows from 0.6 s to 6.3 s, into the band of wave periods. So the compensator is sized for the stroke, and the lift is checked for resonance.
After lift-off the load also has to get clear before the deck comes back up, or the deck strikes it from below. A slow crane cannot always outrun the deck. Our quick lifting article shows how often a crane alone let the deck strike the load at hoist speeds of 1 to 20 m/min in a 250 t case, and how the ANTARES quick lift pulls the load clear by retracting.
Set-down: landing on a moving deck
At set-down the problem runs the other way. A deck rising under the load being lowered meets it at the sum of the two speeds. After touchdown the next wave can lift the deck into the load again or drop it away, so the load bumps or the slings snatch until the crane has paid out enough wire for the deck to carry the load. The landing speed has to stay inside the limit for the load and the deck.
A passive compensator does not slow a rising deck: the load still meets it at the lowering speed plus the deck’s speed. What it softens is the rigging. When the deck drops away after touchdown, the unit extends instead of letting the slings snatch. Between two vessels it can also keep the crane vessel’s own motion out of the load, if its natural period is well above the wave period. Matching the load to a moving deck takes active control that measures that deck.
What each unit does
| Need | Unit |
|---|---|
| Soften the take-up at pickup, and stop the slings snatching after touchdown | RIGEL (55 to 1,000 t) or CYGNUS (12.5 to 10,000 t): a passive gas spring in line, set on deck for the lift |
| Change setting during the lift, and pull the load clear fast | ANTARES (30 to 4,000 t): adaptive passive, with a quick-lift mode that retracts to pull the load clear of the deck |
| Cap a snatch that cannot be avoided | POLARIS (75 to 4,000 t): a shock absorber that holds the force near its valve setting while it strokes, and resets for the next lift |
| Follow the other deck’s motion | Active control that measures the other deck as well as the crane vessel. Standard active heave compensation holds the load still relative to the seabed, not to a moving deck. |
The choice follows from a lift model of both bodies’ motions, the crane, the rigging and the payload in the sea states of the operation. CONSTELLATION models the transfer with and without the compensator and reports the snap loads, the clearance after lift-off and the stroke used.
Sources and assumptions
- The lift-off snap load follows DNV-RP-N103, formerly DNV-RP-H103, 4.7.5 with 4.7.2: snap velocity v_c + v_{rct} and the mass in air, with no added mass (that term applies only in water). The hook load is the static weight plus the snap load (4.4.2).
- The relative motion comes from both vessels’ responses at the crane tip and at the landing spot. Side by side, the two hulls shelter and disturb each other and the water in the gap can resonate, so DNV-RP-N103 (9.2.2) asks for the two vessels to be modelled together.
- Re-contact after lift-off is judged as in DNV-RP-N103 9.5, from the hoisting speed and the period and size of the relative motion; the quick-lift results and their model basis are on our quick lifting page.
- The 100 t example is illustrative: 10 MN/m for the crane, wire and rigging, and a compensator 100 times softer.
Frequently asked questions
What is a transfer lift?
A lift between two bodies that move independently: vessel to platform, vessel to vessel, or barge to crane vessel. The load case is the relative motion between the crane tip and the other deck, not only the crane vessel’s heave.
Why are transfer lifts riskier than ordinary deck lifts?
At pickup and set-down the gap between the load and the other deck changes with both motions. Slack slings can snatch taut at pickup, the deck can come back up and strike the load after lift-off, and a rising deck can meet the load hard at set-down.
What causes a snap load at pickup?
The slings come taut at the relative speed between the load and the crane tip, plus the hoisting speed. DNV-RP-N103 gives the snap load at lift-off as that speed times the square root of the hoisting system’s stiffness times the mass: F_{\text{snap}} = (v_c + v_{rct}) \sqrt{K M}.
Can a passive heave compensator follow the other deck?
No. It makes the hoisting system soft, which turns the snatch into a slower, smaller take-up and keeps the slings from snatching after touchdown. It does not measure or follow the other deck, and it does not slow a deck rising into the load. Matching the load to a moving deck takes active control that measures that deck.
Which compensator fits a transfer lift?
RIGEL or CYGNUS to soften the take-up at pickup and the slings after touchdown, ANTARES where the setting must change during the lift or the load must be pulled clear fast, POLARIS to cap a single snatch load, and active control that measures the other deck where the load must follow it.
Planning a transfer lift?
Send us:
- the payload and its rigging
- the two vessels, or the vessel and the platform, and the crane
- the sea states and the operation sequence
We’ll model the transfer in CONSTELLATION and recommend the compensator.
Send your lift case →